About

I'm an Edge AI engineer at VinRobotics in Hanoi, where I do research with Dr. An Thai Le. I study machine learning on the hardware it actually runs on: small sensors, embedded processors, and analog and neuromorphic accelerators. Two questions run through the work: how to keep a model accurate when its hardware is noisy or drifting, and how to measure it so the result holds outside the lab.

If you work on learning with unconventional hardware or on evaluating robot perception, I'd be glad to hear from you.

The path so far

Each stage moved one layer closer to where a model runs.

  1. Undergraduate research

    One sensor, small models

    Can one ECG lead and a tiny model screen for sleep apnea?

    With Dr. Cuong Do and Dr. Hieu Pham, I worked on sleep-apnea detection from a single ECG lead, published in IEEE JBHI. Giving small models the whole waveform instead of just its R-peaks made them more accurate without making them bigger: on small hardware, a better input beats a bigger model.

  2. Robot builds

    Robots, from the wiring up

    What does real hardware do to an algorithm?

    I then built robots end to end: a Stewart-platform neck, a vision-guided arm, a life-sized humanoid, and, as an intern, firmware for a 24-DOF animatronic head. Power, timing and electrical noise decided whether an algorithm worked at all.

  3. Engineering, now

    Models on real boards

    What does it take for a model to run on the robot itself?

    At VinRobotics I brought up embedded Linux on NXP i.MX93 and Qualcomm RB8 boards and ran a robot's control policy on them. On the i.MX93, one step of the policy takes about a third of a millisecond on a single core.

  4. Research, now

    Learning on imperfect hardware

    Can learning survive the chip, and can we trust the score?

    Deployed analog accelerators drift and usually run forward passes only, so I study how to recover them without gradients and what choosing the step size costs. Event cameras suit fast collision warning, so I test whether its benchmarks reward detecting a collision or shortcuts such as clip length.

News

Research

Current work

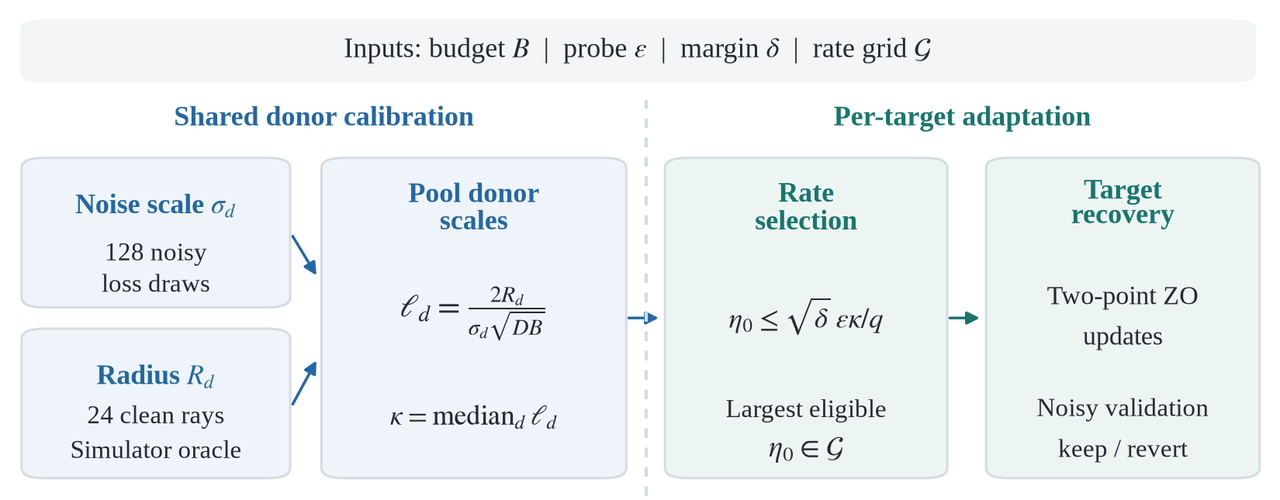
Method diagram: noise scale and radius measured on donor devices are pooled into a step scale, which selects the largest eligible learning rate from a grid before two-point zeroth-order updates recover the target device with noisy keep-or-revert validation

Under review

Budget-Aware Step Selection for Forward-Only Recovery of Analog Accelerators

Duong V. Nguyen and An Thai Le

Analog accelerators drift. Recovering one with forward-only optimization spends device queries twice: on the parameter updates, and on choosing those updates. In a controlled testbed, single-step descent boundaries exceed whole-run failure boundaries by 27.2× in geometric mean, so early progress is a poor guide to a full recovery run. We derive a finite-horizon bound on noise-driven displacement and use its step scale to pick a rate from donor devices without searching on the target. On 36 held-out simulated crossbar targets, a selector with a fine rate grid and condition-matched donors uses 93.62% fewer operational forward evaluations than target search at a 0.399 percentage-point accuracy cost, and a transferred fixed setting is more accurate at lower cost still. The case is for reporting accuracy and configuration cost together.

Paper, code and project page will be linked after review.

Scenario overview (1:20, no sound): collision and near-miss encounters across nine scenario types, with the event camera beside the overhead view.

Under review

Beyond Collision AUC: A Paired CARLA Benchmark for Event-Based Collision Warning

Duong V. Nguyen*, Minh Vu*, and An Thai Le *equal contribution

Collision-warning detectors are usually scored by collision AUC, yet on an existing event-camera corpus, episode duration alone reaches AUC 0.980. We build 440 collision/near-miss pairs in CARLA, covering stationary and moving vehicles and pedestrians, in which each pair shares scene and camera conditions, so a detector must separate contact from a matched non-contact encounter. Spiking and temporal convolutional networks reach test AUCs of 0.60 and 0.57 but matched-pair concordance of 69.8% and 78.6%, so the two measures rank them in opposite orders. Thresholds set for at least 90% collision recall still raise frequent near-miss alarms.

Paper, benchmark and code will be linked after review.

Earlier work

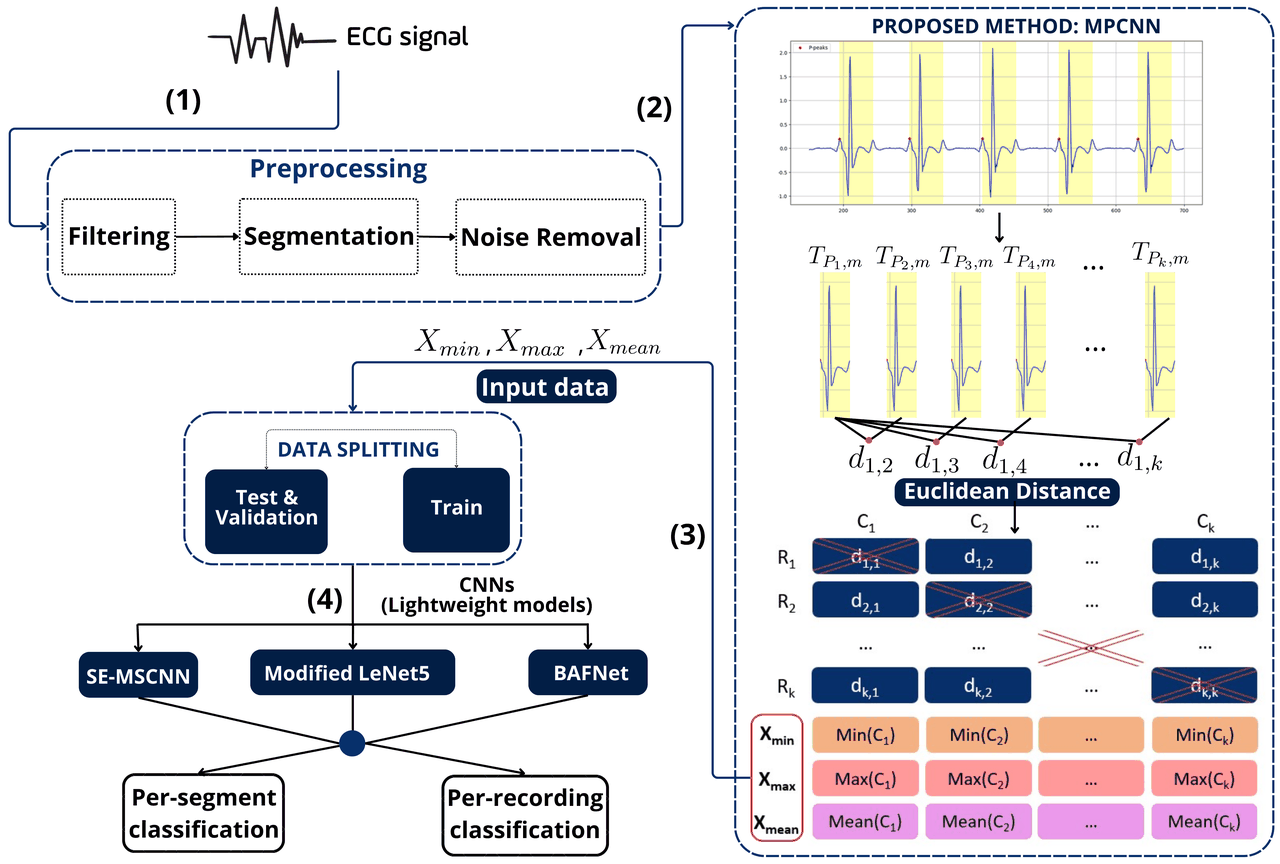
MPCNN overview: the ECG signal is filtered, segmented and denoised; subsequences starting at each P peak are compared by Euclidean distance, and the minimum, maximum and mean of each distance column feed lightweight CNNs (SE-MSCNN, modified LeNet-5, BAFNet) for per-segment and per-recording classification

Published 2024

MPCNN: A Novel Matrix Profile Approach for CNN-Based Single Lead Sleep Apnea in Classification Problem

Hieu X. Nguyen, Duong V. Nguyen, Hieu H. Pham, and Cuong D. Do

IEEE Journal of Biomedical and Health Informatics, vol. 28, no. 8, 2024

Single-lead ECG detectors for sleep apnea usually work from R-peaks and RR intervals, which leave out most of the PQRST waveform. MPCNN borrows from Matrix Profile algorithms: it builds Euclidean distance profiles between fixed-length subsequences of the signal and feeds their minimum, maximum and mean (MinDP, MaxDP, MeanDP) to lightweight CNNs. Per-segment accuracy reaches 92.11% on PhysioNet Apnea-ECG (70 overnight recordings) and 81.25% on UCDDB (25). On PhysioNet, per-recording accuracy is 100% with a correlation of 0.989, which points toward home sleep apnea testing on IoT devices.

Each subsequence starts at a P peak, and windows that span the whole beat, from the P peak to the end of the ST segment, work best. The profiles also slot into existing lightweight detectors, BAFNet (0.29 MB) and SE-MSCNN (0.16 MB), in place of their R-peak and RR-interval inputs, and improve them with the architectures unchanged: the gain comes from what the model sees, not from a bigger model.

Experience

Work

VinRobotics Edge AI Engineer

Research

  • Research end to end, from question and protocol to experiments, statistics and writing; first author of both papers under review.
  • Experiment software for simulated analog, photonic and spiking accelerators (AIHWKit, pytorch-onn, Rockpool), and an event-camera data pipeline built on CARLA.
  • Evaluation built to be audited: paired tests, grouped bootstrap and multiple-comparison correction, pinned environments, and provenance that traces every reported number to its configuration, data and script.

Edge AI on NXP i.MX93

  • Board bring-up on embedded Linux: device trees, a MIPI camera driver ported into NXP's kernel, and a real-time image built with Yocto.
  • A path from PyTorch to the board: NCNN packaged with a cross-compilation SDK, and a robot control policy that runs in about a third of a millisecond on one Cortex-A55 core.

Edge AI on Qualcomm RB8

  • Brought up the board with Qualcomm Linux, built with Yocto, and with Ubuntu; set up cross-compilation and deployment; and benchmarked a humanoid robot's control policy on its CPU for inference time, CPU load and latency.

Internships and research

Augmented Reality Interactive Solution (ARIS)

Augmented reality for medical education; see AR anatomy.

VinUni-Illinois Smart Health Center Undergraduate researcher

Single-lead ECG methods for sleep apnea and cardiovascular screening, supervised by Dr. Cuong Do and Dr. Hieu Pham; co-authored MPCNN.

Education

VinUniversity B.Sc. Electrical and Computer Engineering

College of Engineering & Computer Science. English-medium program validated by Cornell University.

Phan Boi Chau High School for the Gifted Physics specialized class

Awards

Projects

Stewart platform neck

A six-servo Stewart platform built as a neck for the Unitree G1 humanoid. It turns the head to follow a face at 30 FPS with 48.6 ms end-to-end latency. I designed the electrical system, a 6 V, 10 A servo supply with PCA9685 PWM from an Arduino Uno, and developed the tracking and control code. Decoupling, separate power and signal wiring and split grounds cut PWM jitter from ±8 µs to ±1.5 µs and stopped resets under current peaks above 7 A.

Read more

4-DOF arm with computer vision

A pick-and-place arm that finds red, blue and white blocks with a 1080p, 60 FPS camera, with all vision running on an NVIDIA Jetson Nano and an Arduino Uno driving the servos. I built the block detection, the camera calibration and the pixel-to-world transform. Detection IoU ranged from 0.92 to 0.96, and pick-and-place succeeded in 77–84% of trials.

Read more

24-DOF animatronic head

Real-time firmware on Teensy 4.1 and Zephyr RTOS that drives 24 degrees of freedom for lip sync, eye motion and facial expressions, commanded from ROS 2. I also tracked down motion conflicts and latency and noise problems with signal-level testing.

InMoovXtra

A life-sized humanoid robot built on the open-source InMoov platform, with a silicone face that shows expressions and spoken conversation through an LLM. I worked on its power, wiring and servo control.

Read more

AR anatomy for medical training

A Unity/Vuforia augmented-reality app that places 3D anatomical models, such as a colour-coded skull and facial muscle layers, in front of medical students.